
登录注册
 微信扫码登录
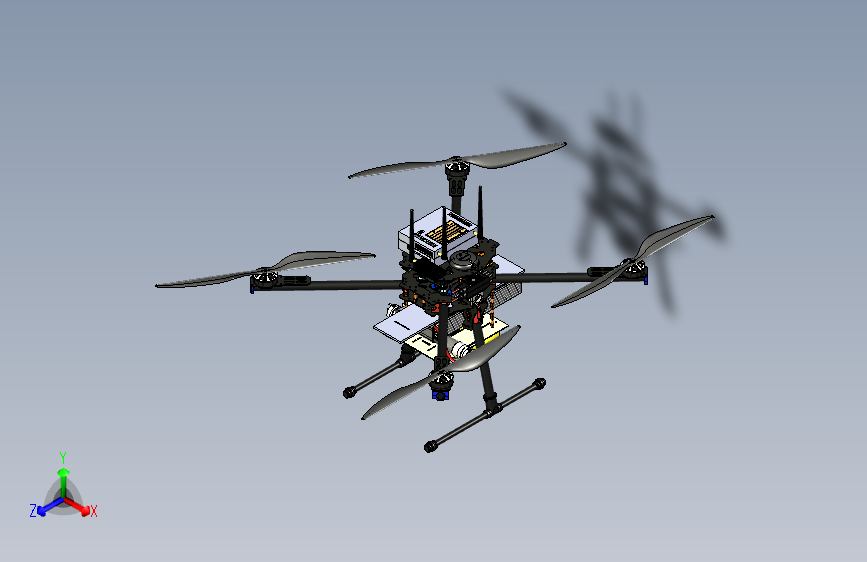
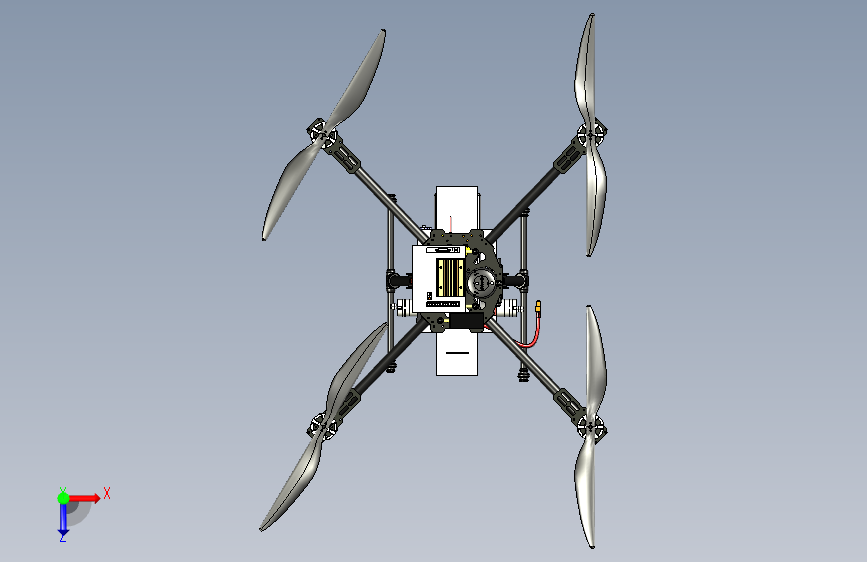
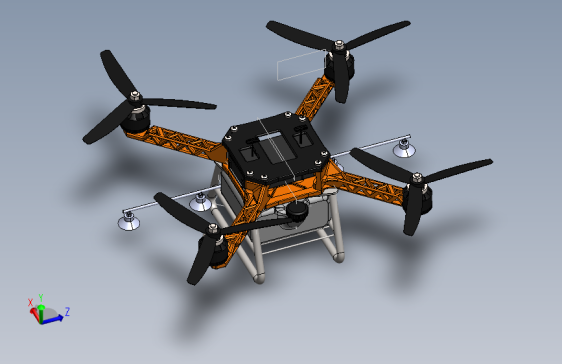
Y0703-无人机+firefighting-quadcopter+SW+STP
(ID:1604095) 改图/画图
截图
AI截图渲染
✨AI图片渲染
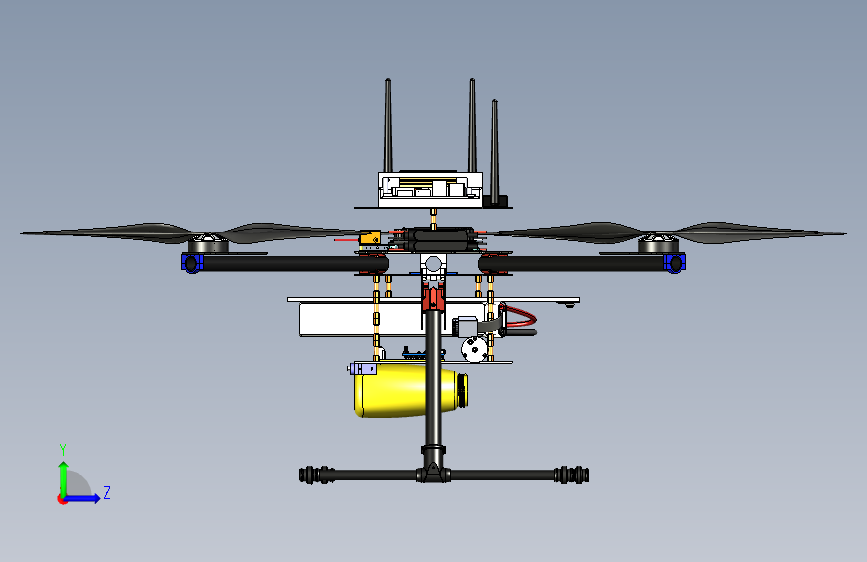
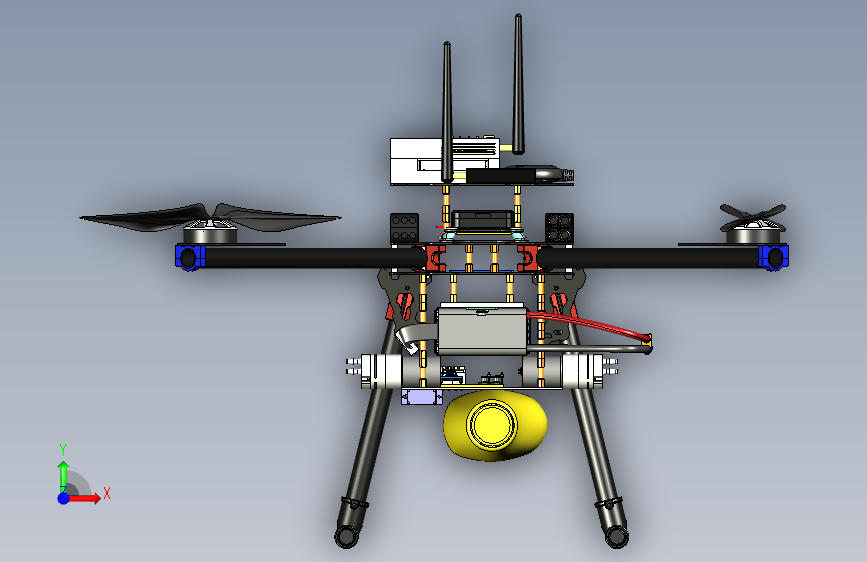
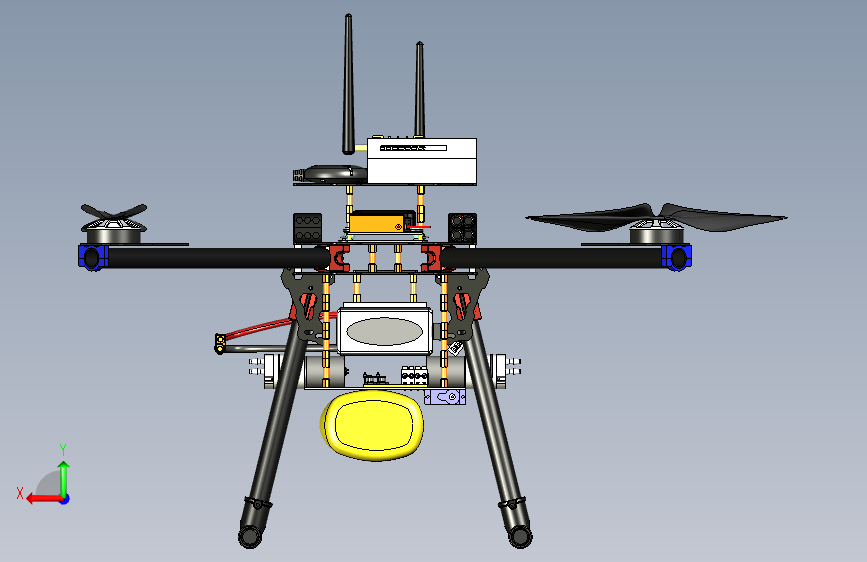
| # | 文件名称 | 文件大小 |
|---|---|---|
| 1 | zongzhuangtu.stp | 52.09M |
| 2 | 100Apowerboard.SLDPRT | 747.96K |
| 3 | 12VPump.SLDPRT | 355.45K |
| 4 | antenna.SLDPRT | 69.24K |
| 5 | ArduinoNano.SLDPRT | 4.40M |
| 6 | arm-clampv2.SLDPRT | 76.81K |
| 7 | arm-clampv3.SLDPRT | 94.50K |
| 8 | arm-clip.SLDPRT | 3.03M |
| 9 | arm-pivot.SLDPRT | 2.69M |
| 10 | arm.SLDPRT | 54.83K |
| 11 | base_pixhawk.SLDPRT | 946.77K |
| 12 | battery_plate.SLDPRT | 64.80K |
| 13 | BP1048204.SLDPRT | 148.07K |
| 14 | bracketlandinggear.SLDPRT | 167.90K |
| 15 | CamV2.1v1.step.SLDPRT | 1.03M |
| 16 | connectorsDG390-5.0-2p.SLDPRT | 191.76K |
| 17 | drv8833.SLDPRT | 1.03M |
| 18 | GensAceTattu-6S9000mAh-25C-Battery-XT60Connector.SLDPRT | 4.54M |
| 19 | JetsonNano2GBCAD.SLDPRT | 9.04M |
| 20 | jnano_case_bottom.SLDPRT | 309.86K |
| 21 | jnano_case_top.SLDPRT | 305.19K |
| 22 | landing-gear-connector.SLDPRT | 444.78K |
| 23 | landing-gear-foot.SLDPRT | 217.39K |
| 24 | leg.SLDPRT | 56.64K |
| 25 | LowerBase.SLDPRT | 469.44K |
| 26 | motor_casing.SLDPRT | 641.66K |
| 27 | payload-rod-cap.SLDPRT | 106.66K |
| 28 | pcb.SLDPRT | 61.58K |
| 29 | Pixhawk.SLDPRT | 3.36M |
| 30 | Propellers_15x5.SLDPRT | 529.50K |
| 31 | PX4NeoM8NGPS.SLDPRT | 1.25M |
| 32 | reciever.SLDPRT | 188.56K |
| 33 | servo.SLDPRT | 175.84K |
| 34 | servo_shaft.SLDPRT | 81.95K |
| 35 | small-tube.SLDPRT | 53.00K |
| 36 | spacer22mmsilver.SLDPRT | 81.10K |
| 37 | spacer22mmsilver_1.SLDPRT | 81.32K |
| 38 | spacer22mmsilver_2.SLDPRT | 101.36K |
| 39 | SurfaceBottleSurfacing.SLDPRT | 586.89K |
| 40 | Tarot-Lowerclamp.SLDPRT | 75.05K |
| 41 | Tarot-Motortoarmattachement.SLDPRT | 382.38K |
| 42 | Tarot-Upperclamp.SLDPRT | 78.64K |
| 43 | Tarot650Assembly.SLDASM | 14.60M |
| 44 | telemetry.SLDPRT | 118.17K |
| 45 | UBECDuo.SLDPRT | 687.02K |
| 46 | UpperBase.SLDPRT | 503.97K |
| 47 | vibration-damper.SLDPRT | 222.28K |
| 48 | water_mechanism.SLDASM | 3.12M |
| 49 | water_mechanism_plate.SLDPRT | 2.25M |
| 50 | XRotorPro40A-COB.SLDPRT | 205.67K |
| 51 | 100Apowerboard.STEP | 507.59K |
| 52 | 12VPump.STEP | 424.32K |
| 53 | antenna.STEP | 33.49K |
| 54 | ArduinoNano.STEP | 12.16M |
| 55 | arm-clampv2.STEP | 30.74K |
| 56 | arm-clampv3.STEP | 69.02K |
| 57 | arm-clip.STEP | 6.28M |
| 58 | arm-pivot.STEP | 5.30M |
| 59 | arm.STEP | 16.68K |
| 60 | base_pixhawk.STEP | 1.14M |
| 61 | battery_plate.STEP | 45.27K |
| 62 | BP1048204.STEP | 67.40K |
| 63 | bracketlandinggear.STEP | 396.78K |
| 64 | connectorsDG390-5.0-2p.STEP | 270.71K |
| 65 | drv8833.STEP | 2.02M |
| 66 | GensAceTattu-6S9000mAh-25C-Battery-XT60Connector.STEP | 13.27M |
| 67 | jnano_case_bottom.STEP | 295.06K |
| 68 | jnano_case_top.STEP | 187.79K |
| 69 | landing-gear-connector.STEP | 513.62K |
| 70 | landing-gear-foot.STEP | 80.32K |
| 71 | leg.STEP | 16.69K |
| 72 | LowerBase.STEP | 1.11M |
| 73 | motor_casing.STEP | 1.12M |
| 74 | payload-deck.STEP | 823.77K |
| 75 | payload-rod-cap.STEP | 32.75K |
| 76 | pcb.STEP | 15.46K |
| 77 | Pixhawk.STEP | 6.42M |
| 78 | Propellers_15x5.STEP | 1.52M |
| 79 | PX4NeoM8NGPS.STEP | 1.99M |
| 80 | reciever.STEP | 146.08K |
| 81 | servo.STEP | 217.58K |
| 82 | servo_shaft.STEP | 16.73K |
| 83 | small-tube.STEP | 16.72K |
| 84 | spacer22mmsilver.STEP | 85.54K |
| 85 | spacer22mmsilver_1.STEP | 85.55K |
| 86 | spacer22mmsilver_2.STEP | 112.77K |
| 87 | SurfaceBottleSurfacing.STEP | 3.11M |
| 88 | Tarot-Lowerclamp.STEP | 40.29K |
| 89 | Tarot-Motortoarmattachement.STEP | 187.49K |
| 90 | Tarot-Upperclamp.STEP | 41.13K |
| 91 | telemetry.STEP | 112.84K |
| 92 | UBECDuo.STEP | 1.72M |
| 93 | UpperBase.STEP | 1.19M |
| 94 | water_mechanism_plate.STEP | 262.33K |
| 95 | XRotorPro40A-COB.STEP | 377.28K |
此图纸下载需要5金币
立即下载
发布者
模型信息
图纸ID:1604095
图纸格式:stp,sldprt,sldasm,step
文件大小:87M
所需金币:5
上传时间:2024-10-03 14:52:41
是否可编辑:可修改,包括参数
软件版本:STEP
标签
图纸简介
版权说明
用户在本站上传的作品如侵犯到您的权益,请与本站管理员联系删除。用户在本站下载的原创作品,只拥有作品的使用权,著作权归原作者所有,未经合法授权,用户不得以任何形式发布、传播、复制、转售该作品。
作者其它图纸 查看更多



AI渲染-将平面图渲染为真实效果图
原图
渲染图
正在渲染中,请稍候...

 QQ在线客服
 官方QQ群