
登录注册
 微信扫码登录
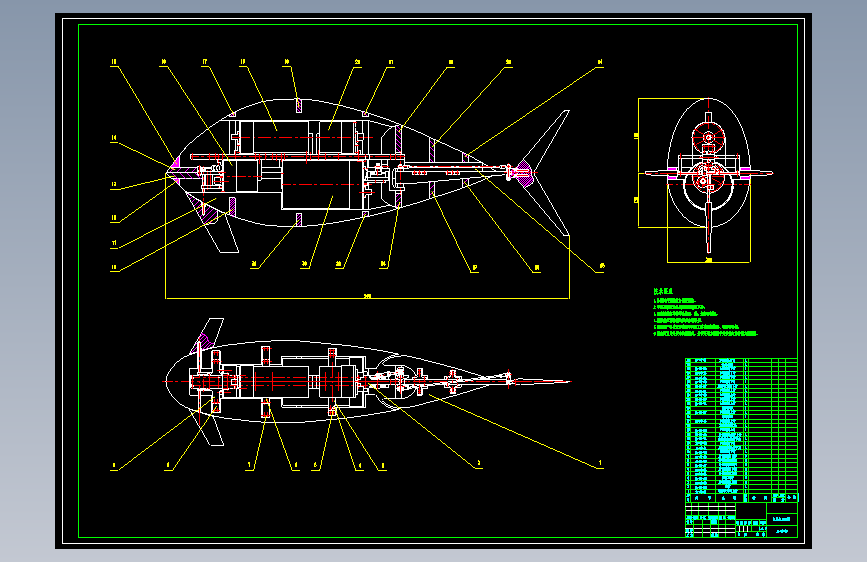
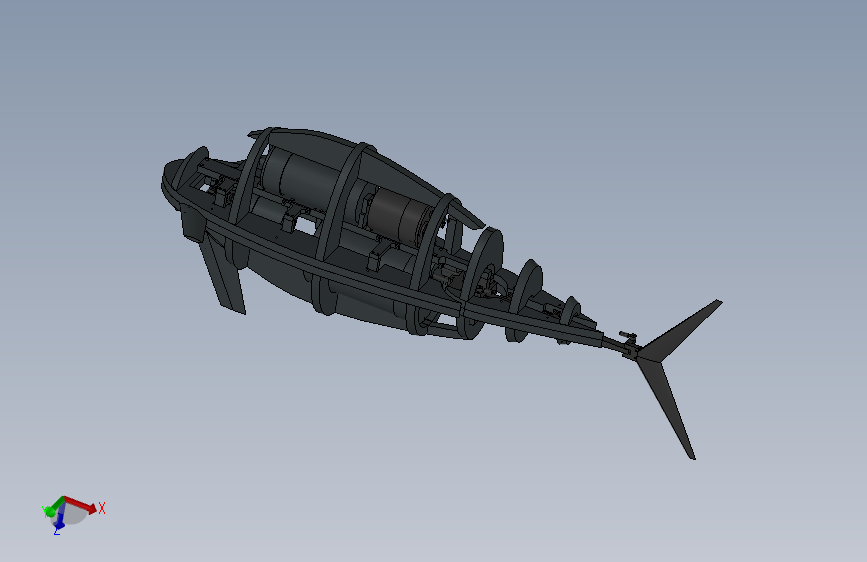
仿生鱼形水下机器人
(ID:2087563) 改图/画图
截图
AI截图渲染
✨AI图片渲染
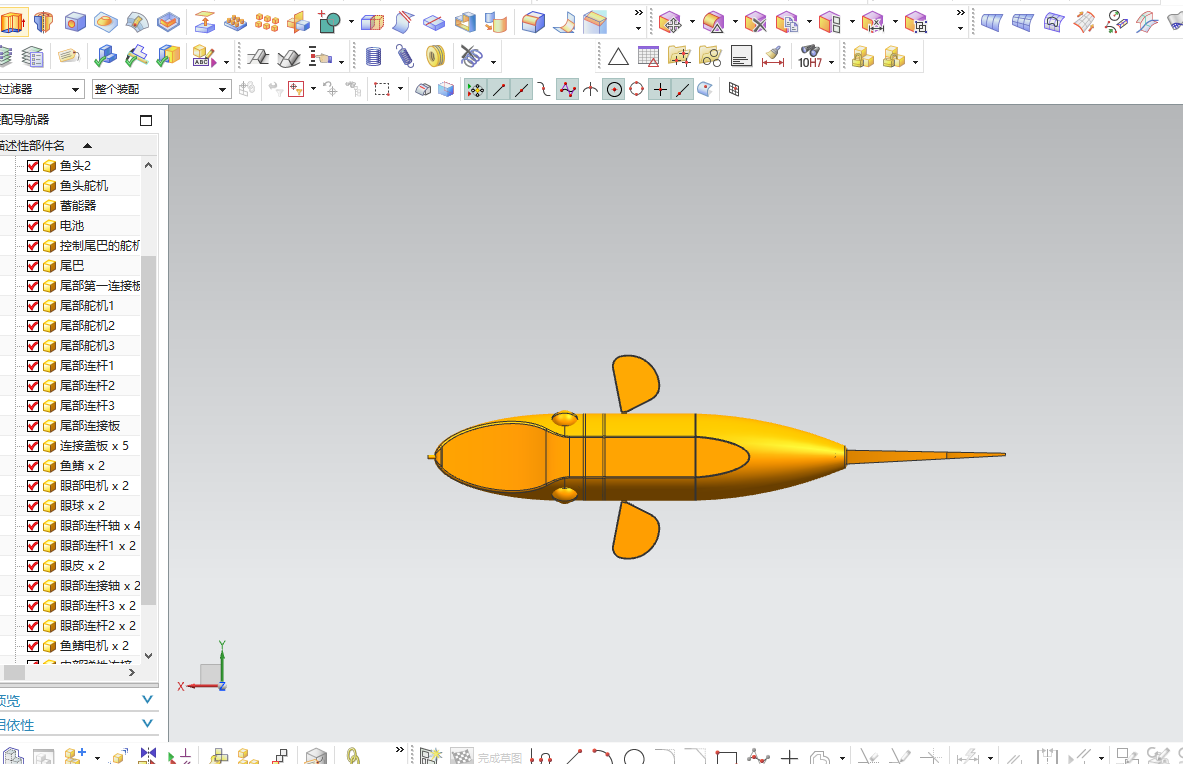
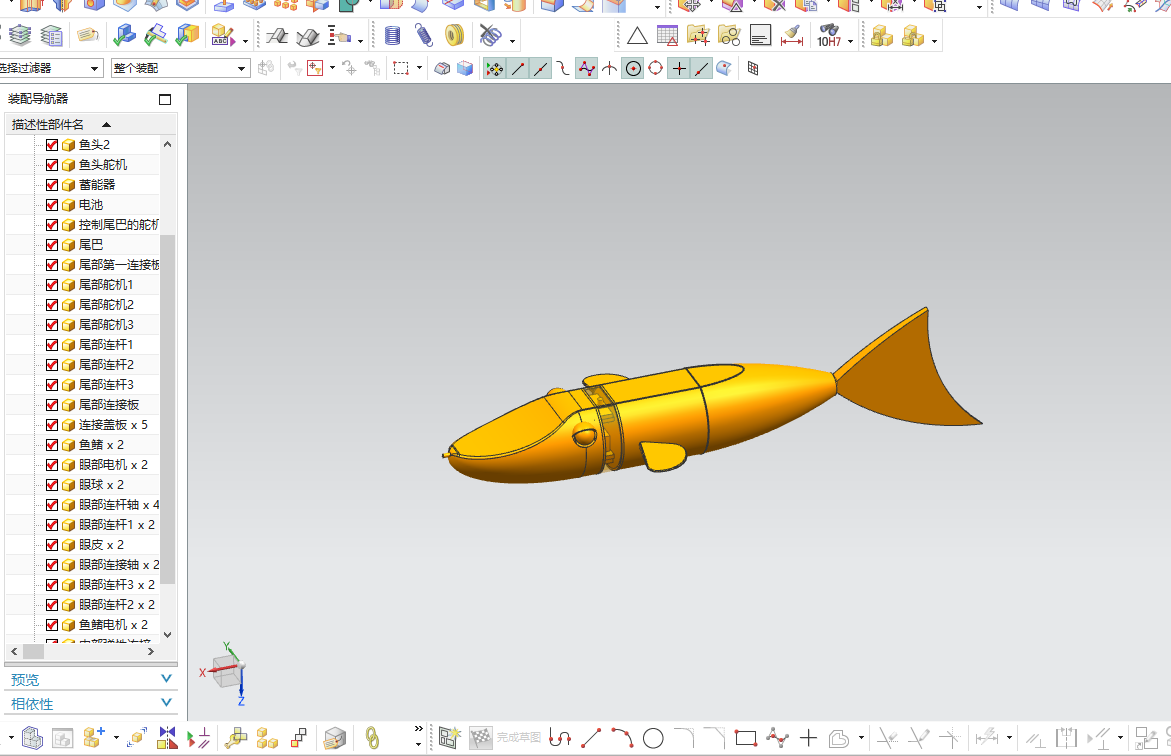
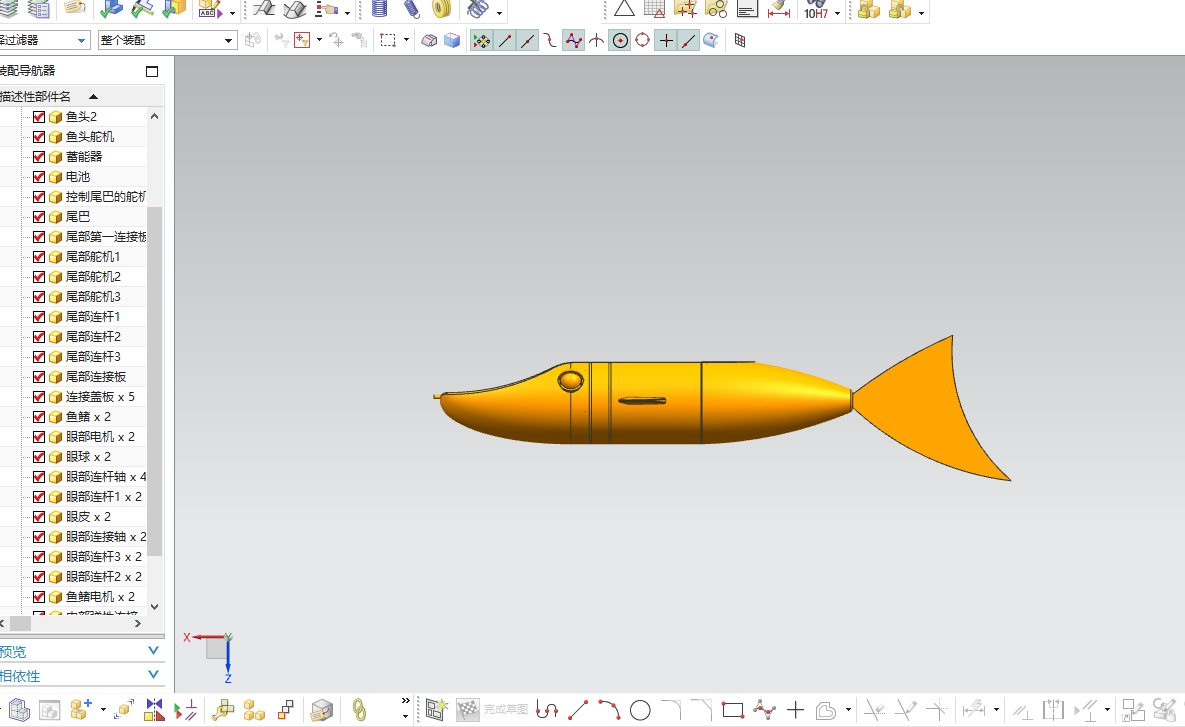
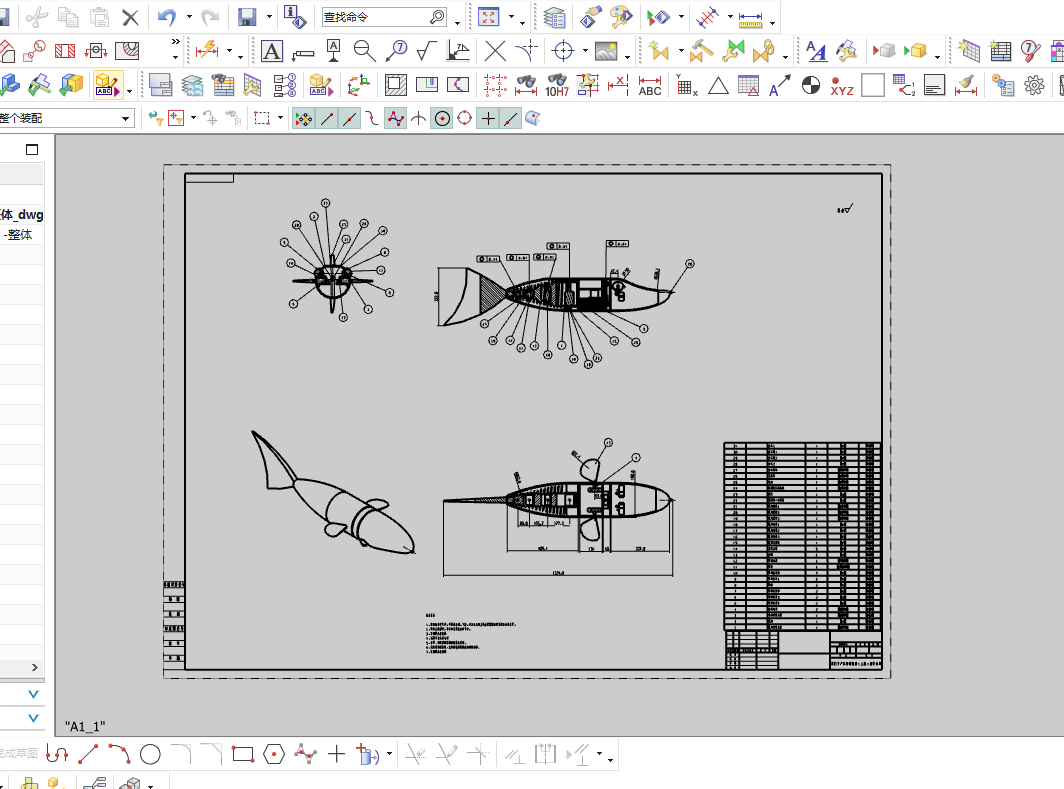
| # | 文件名称 | 文件大小 |
|---|---|---|
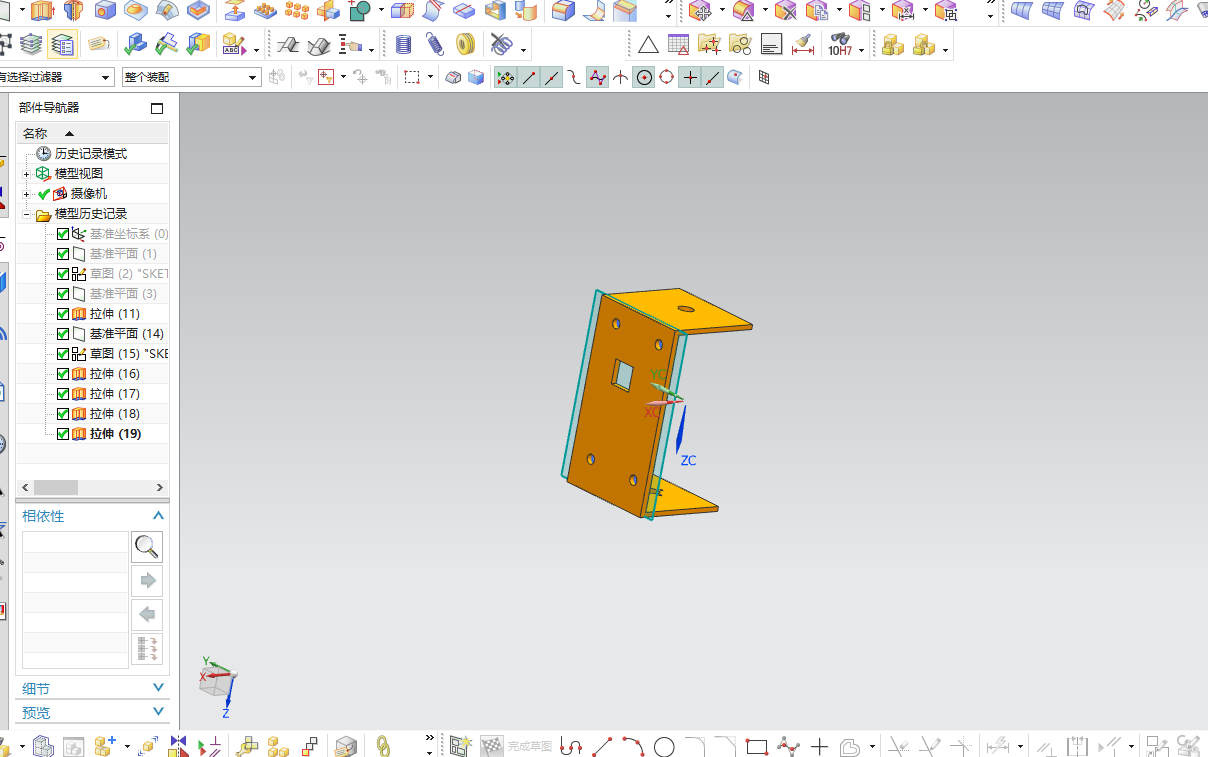
| 1 | 仿生鱼形水下机器人CAD.PNG | 26.76K |
| 2 | 仿生鱼形水下机器人侧面.PNG | 105.06K |
| 3 | 仿生鱼形水下机器人俯视.PNG | 125.64K |
| 4 | 仿生鱼形水下机器人内部细节.PNG | 186.46K |
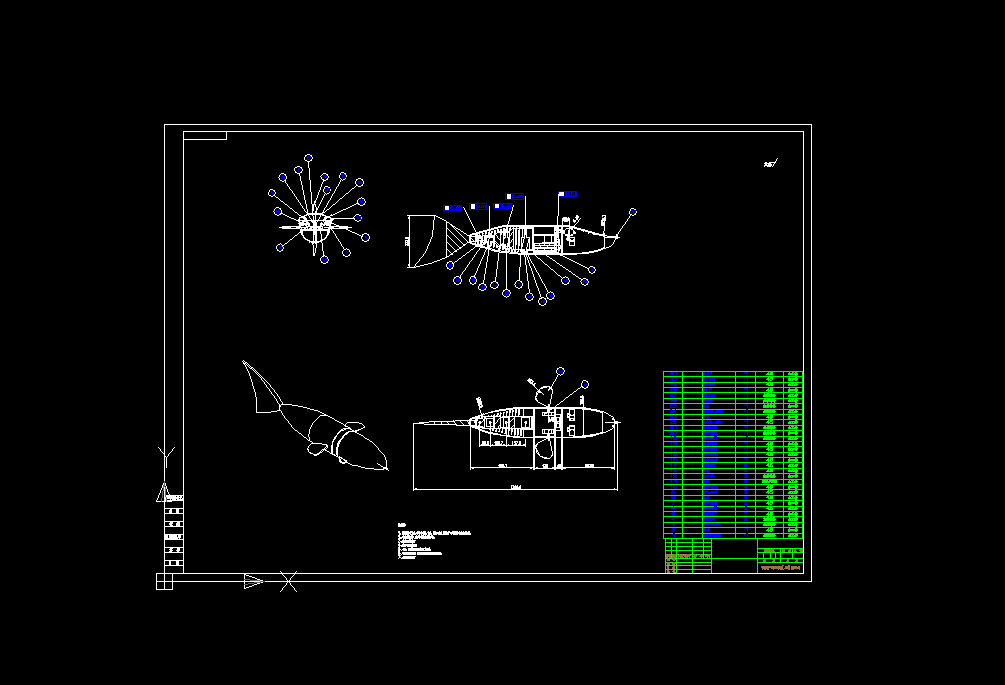
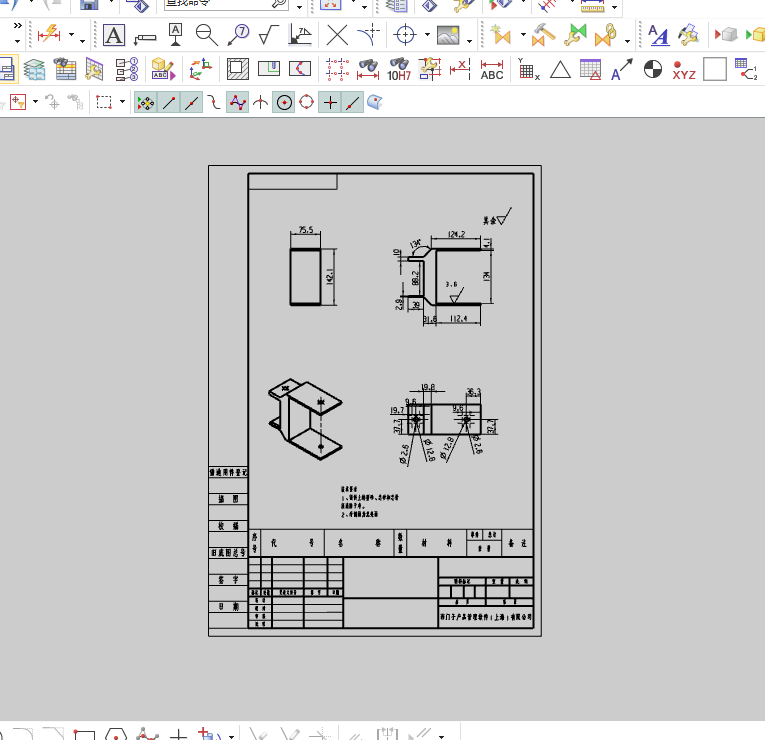
| 5 | 仿生鱼形水下机器人工程图.PNG | 99.96K |
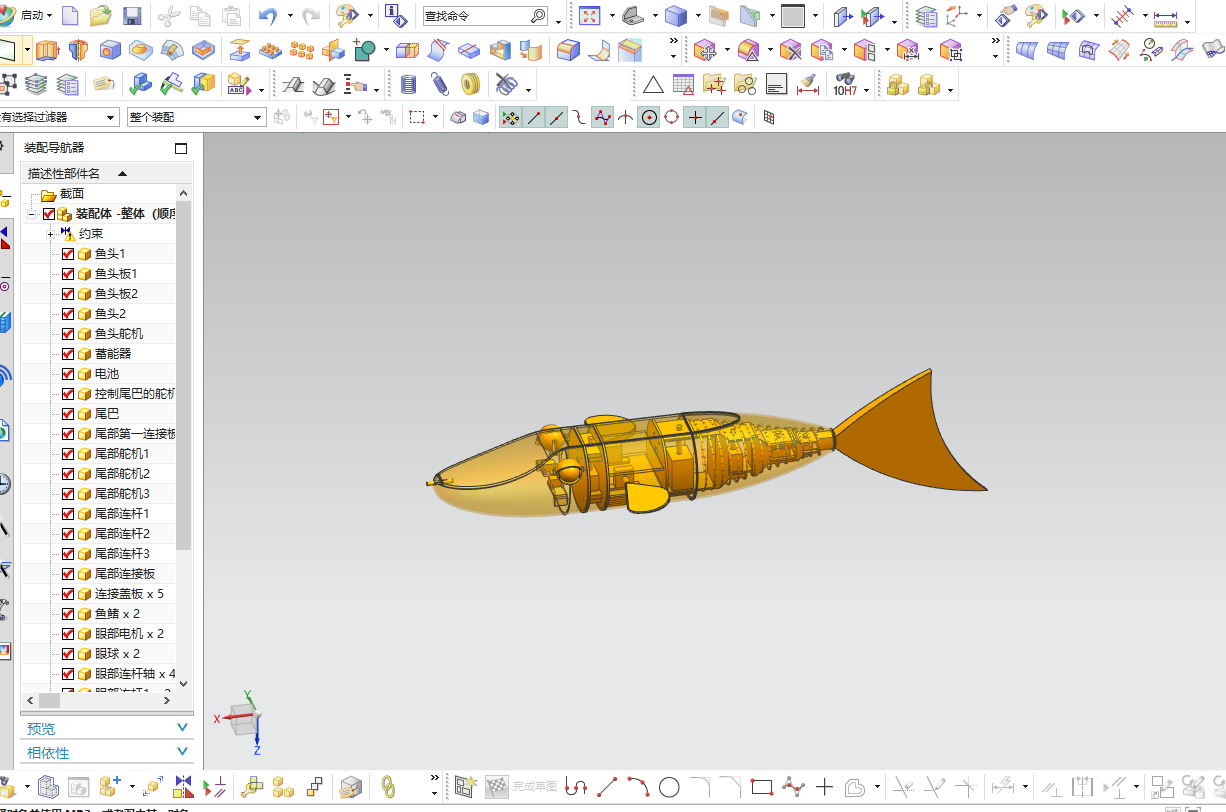
| 6 | 仿生鱼形水下机器人装配.PNG | 131.32K |
| 7 | 仿生鱼形水下机器人运动模拟细节.PNG | 87.57K |
| 8 | 尾部连接板.PNG | 113.85K |
| 9 | 尾部连杆工程图.PNG | 59.13K |
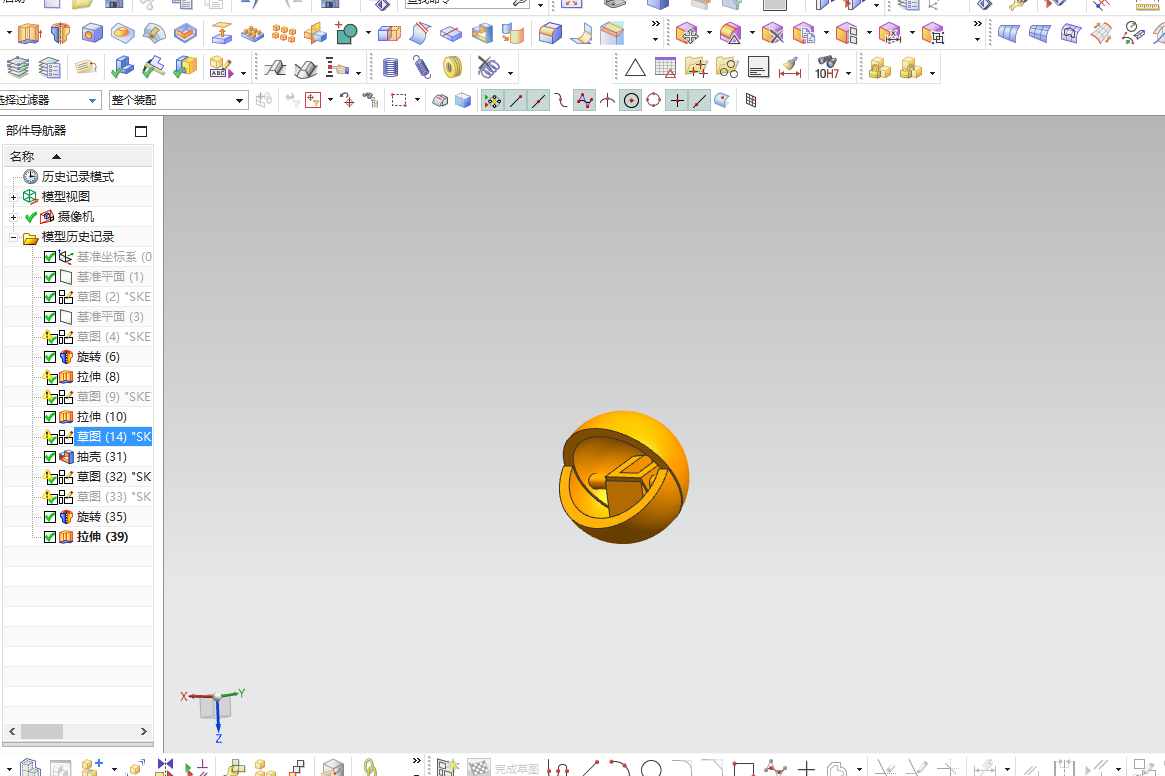
| 10 | 眼皮结构建模细节.PNG | 120.16K |
| 11 | 运动仿真动态图.gif | 115.72K |
| 12 | M-16.prt | 230.50K |
| 13 | M1.6-0.35.prt | 182.00K |
| 14 | M1.6-8.prt | 182.00K |
| 15 | M3-14.prt | 180.50K |
| 16 | M5-30.prt | 255.00K |
| 17 | 上浮下潜运动结构.prt | 448.00K |
| 18 | 中部弹性连接.prt | 306.50K |
| 19 | 尾巴.prt | 664.00K |
| 20 | 尾巴2010.dwg | 39.21K |
| 21 | 尾巴2010.log | 3.78K |
| 22 | 尾巴2010_bk.dwg | 83.35K |
| 23 | 尾巴_dwg1.prt | 285.50K |
| 24 | 尾部.prt | 373.50K |
| 25 | 尾部弹性支撑.prt | 1.77M |
| 26 | 尾部第一连接板.prt | 436.00K |
| 27 | 尾部第一连接板2010.dwg | 38.33K |
| 28 | 尾部第一连接板2010.log | 3.70K |
| 29 | 尾部第一连接板2010_bk.dwg | 82.85K |
| 30 | 尾部第一连接板_dwg1.prt | 285.50K |
| 31 | 尾部舵机1.prt | 304.50K |
| 32 | 尾部舵机2.prt | 303.50K |
| 33 | 尾部舵机3-2010.dwg | 31.17K |
| 34 | 尾部舵机3.prt | 307.00K |
| 35 | 尾部舵机3_dwg1.prt | 246.00K |
| 36 | 尾部连接板.prt | 406.50K |
| 37 | 尾部连杆1.prt | 760.00K |
| 38 | 尾部连杆1_2010.dwg | 46.22K |
| 39 | 尾部连杆1_dwg1.prt | 310.00K |
| 40 | 尾部连杆2.prt | 716.00K |
| 41 | 尾部连杆3.prt | 632.00K |
| 42 | 尾部连杆3_2010.dwg | 42.46K |
| 43 | 尾部连杆3_dwg1.prt | 296.50K |
| 44 | 控制尾巴的舵机.prt | 304.50K |
| 45 | 摆动结构设计.prt | 520.00K |
| 46 | 整体.prt | 6.25M |
| 47 | 模型-头转动.prt | 5.33M |
| 48 | 模型.prt | 4.83M |
| 49 | 模型0519.prt | 4.80M |
| 50 | 模型2.prt | 4.83M |
| 51 | 电池.prt | 780.00K |
| 52 | 电路密封舱设计.prt | 342.50K |
| 53 | 眼球.prt | 352.50K |
| 54 | 眼皮.prt | 592.00K |
| 55 | 眼部电机.prt | 310.00K |
| 56 | 眼部连接轴.prt | 273.50K |
| 57 | 眼部连杆1.prt | 289.00K |
| 58 | 眼部连杆2.prt | 286.00K |
| 59 | 眼部连杆3.prt | 305.00K |
| 60 | 眼部连杆轴.prt | 273.00K |
| 61 | 蓄能器.prt | 242.00K |
| 62 | 装配体-整体.dwg | 585.47K |
| 63 | 装配体-整体.prt | 668.00K |
| 64 | 装配体-整体_dwg1.prt | 2.28M |
| 65 | 装配体.prt | 632.00K |
| 66 | 运动动画.avi | 5.66M |
| 67 | 连接盖板.prt | 299.00K |
| 68 | 鱼头1.prt | 1.22M |
| 69 | 鱼头2.prt | 764.00K |
| 70 | 鱼头板1.prt | 536.00K |
| 71 | 鱼头板2.prt | 544.00K |
| 72 | 鱼头舵机.prt | 394.00K |
| 73 | 鱼身.prt | 1.31M |
| 74 | 鱼鳍.prt | 472.00K |
| 75 | 鱼鳍电机.prt | 315.50K |
| 76 | motion_1-solution_1.msg | 55.95K |
| 77 | motion_1-solution_1.rad | 1.48M |
| 78 | motion_1-solution_1.rmd | 37.86K |
| 79 | motion_1-solution_1.rplt | 2.33M |
| 80 | motion_1-solution_10.msg | 40.42K |
| 81 | motion_1-solution_10.rad | 21.82K |
| 82 | motion_1-solution_10.rmd | 35.87K |
| 83 | motion_1-solution_10.rplt | 52.16K |
| 84 | motion_1-solution_11.msg | 49.67K |
| 85 | motion_1-solution_11.rad | 1.48M |
| 86 | motion_1-solution_11.rmd | 35.87K |
| 87 | motion_1-solution_11.rplt | 2.33M |
| 88 | motion_1-solution_12.msg | 40.42K |
| 89 | motion_1-solution_12.rad | 21.82K |
| 90 | motion_1-solution_12.rmd | 35.87K |
| 91 | motion_1-solution_12.rplt | 52.16K |
| 92 | motion_1-solution_13.msg | 46.48K |
| 93 | motion_1-solution_13.rad | 12.74K |
| 94 | motion_1-solution_13.rmd | 38.24K |
| 95 | motion_1-solution_13.rplt | 38.03K |
| 96 | motion_1-solution_14.msg | 38.99K |
| 97 | motion_1-solution_14.rad | 6.68K |
| 98 | motion_1-solution_14.rmd | 35.87K |
| 99 | motion_1-solution_14.rplt | 28.61K |
| 100 | motion_1-solution_15.msg | 40.42K |
| 101 | motion_1-solution_15.rad | 21.82K |
| 102 | motion_1-solution_15.rmd | 35.87K |
| 103 | motion_1-solution_15.rplt | 52.16K |
| 104 | motion_1-solution_16.msg | 49.67K |
| 105 | motion_1-solution_16.rad | 1.48M |
| 106 | motion_1-solution_16.rmd | 35.83K |
| 107 | motion_1-solution_16.rplt | 2.33M |
| 108 | motion_1-solution_17.msg | 38.99K |
| 109 | motion_1-solution_17.rad | 6.68K |
| 110 | motion_1-solution_17.rmd | 35.91K |
| 111 | motion_1-solution_17.rplt | 28.61K |
| 112 | motion_1-solution_18.msg | 49.67K |
| 113 | motion_1-solution_18.rad | 1.48M |
| 114 | motion_1-solution_18.rmd | 35.87K |
| 115 | motion_1-solution_18.rplt | 2.33M |
| 116 | motion_1-solution_19.msg | 46.48K |
| 117 | motion_1-solution_19.rad | 12.74K |
| 118 | motion_1-solution_19.rmd | 38.24K |
| 119 | motion_1-solution_19.rplt | 38.03K |
| 120 | motion_1-solution_2.msg | 55.32K |
| 121 | motion_1-solution_2.rad | 1.48M |
| 122 | motion_1-solution_2.rmd | 37.62K |
| 123 | motion_1-solution_2.rplt | 2.33M |
| 124 | motion_1-solution_20.msg | 51.69K |
| 125 | motion_1-solution_20.rad | 9.71K |
| 126 | motion_1-solution_20.rmd | 38.24K |
| 127 | motion_1-solution_20.rplt | 33.32K |
| 128 | motion_1-solution_21.msg | 1.29M |
| 129 | motion_1-solution_21.rad | 1.05M |
| 130 | motion_1-solution_21.rmd | 38.24K |
| 131 | motion_1-solution_21.rplt | 1.66M |
| 132 | motion_1-solution_3.msg | 50.92K |
| 133 | motion_1-solution_3.rad | 1.48M |
| 134 | motion_1-solution_3.rmd | 35.95K |
| 135 | motion_1-solution_3.rplt | 2.33M |
| 136 | motion_1-solution_4.msg | 49.67K |
| 137 | motion_1-solution_4.rad | 1.48M |
| 138 | motion_1-solution_4.rmd | 35.47K |
| 139 | motion_1-solution_4.rplt | 2.33M |
| 140 | motion_1-solution_5.msg | 50.10K |
| 141 | motion_1-solution_5.rad | 1.48M |
| 142 | motion_1-solution_5.rmd | 35.87K |
| 143 | motion_1-solution_5.rplt | 2.33M |
| 144 | motion_1-solution_6.msg | 49.67K |
| 145 | motion_1-solution_6.rad | 1.48M |
| 146 | motion_1-solution_6.rmd | 35.88K |
| 147 | motion_1-solution_6.rplt | 2.33M |
| 148 | motion_1-solution_7.msg | 56.57K |
| 149 | motion_1-solution_7.rad | 1.48M |
| 150 | motion_1-solution_7.rmd | 38.08K |
| 151 | motion_1-solution_7.rplt | 2.33M |
| 152 | motion_1-solution_8.msg | 49.67K |
| 153 | motion_1-solution_8.rad | 1.48M |
| 154 | motion_1-solution_8.rmd | 35.86K |
| 155 | motion_1-solution_8.rplt | 2.33M |
| 156 | motion_1-solution_9.msg | 49.67K |
| 157 | motion_1-solution_9.rad | 1.48M |
| 158 | motion_1-solution_9.rmd | 35.87K |
| 159 | motion_1-solution_9.rplt | 2.33M |
| 160 | motion_1.sim | 528.00K |
| 161 | 装配体.afu | 1.50K |
此图纸下载需要340金币
立即下载
发布者
模型信息
图纸ID:2087563
图纸格式:prt,dwg
文件大小:63.64M
所需金币:340
上传时间:2025-05-04 22:38:39
是否可编辑:可修改,包括参数
软件版本:UG 10
标签
图纸简介
仿生鱼形水下机器人,模型为ug绘制,为装配文件,为一款仿鱼形水下机器人,模型主要由鱼头,眼皮,鱼鳍,尾部,尾巴,舵机,连杆,电机,眼球,电池等装配组成,模型文档保护工程图,CAD,运动仿真。模型仅供参考学习,欢迎下载。
版权说明
用户在本站上传的作品如侵犯到您的权益,请与本站管理员联系删除。用户在本站下载的原创作品,只拥有作品的使用权,著作权归原作者所有,未经合法授权,用户不得以任何形式发布、传播、复制、转售该作品。





AI渲染-将平面图渲染为真实效果图
原图
渲染图
正在渲染中,请稍候...

 QQ在线客服
 官方QQ群